(About us)
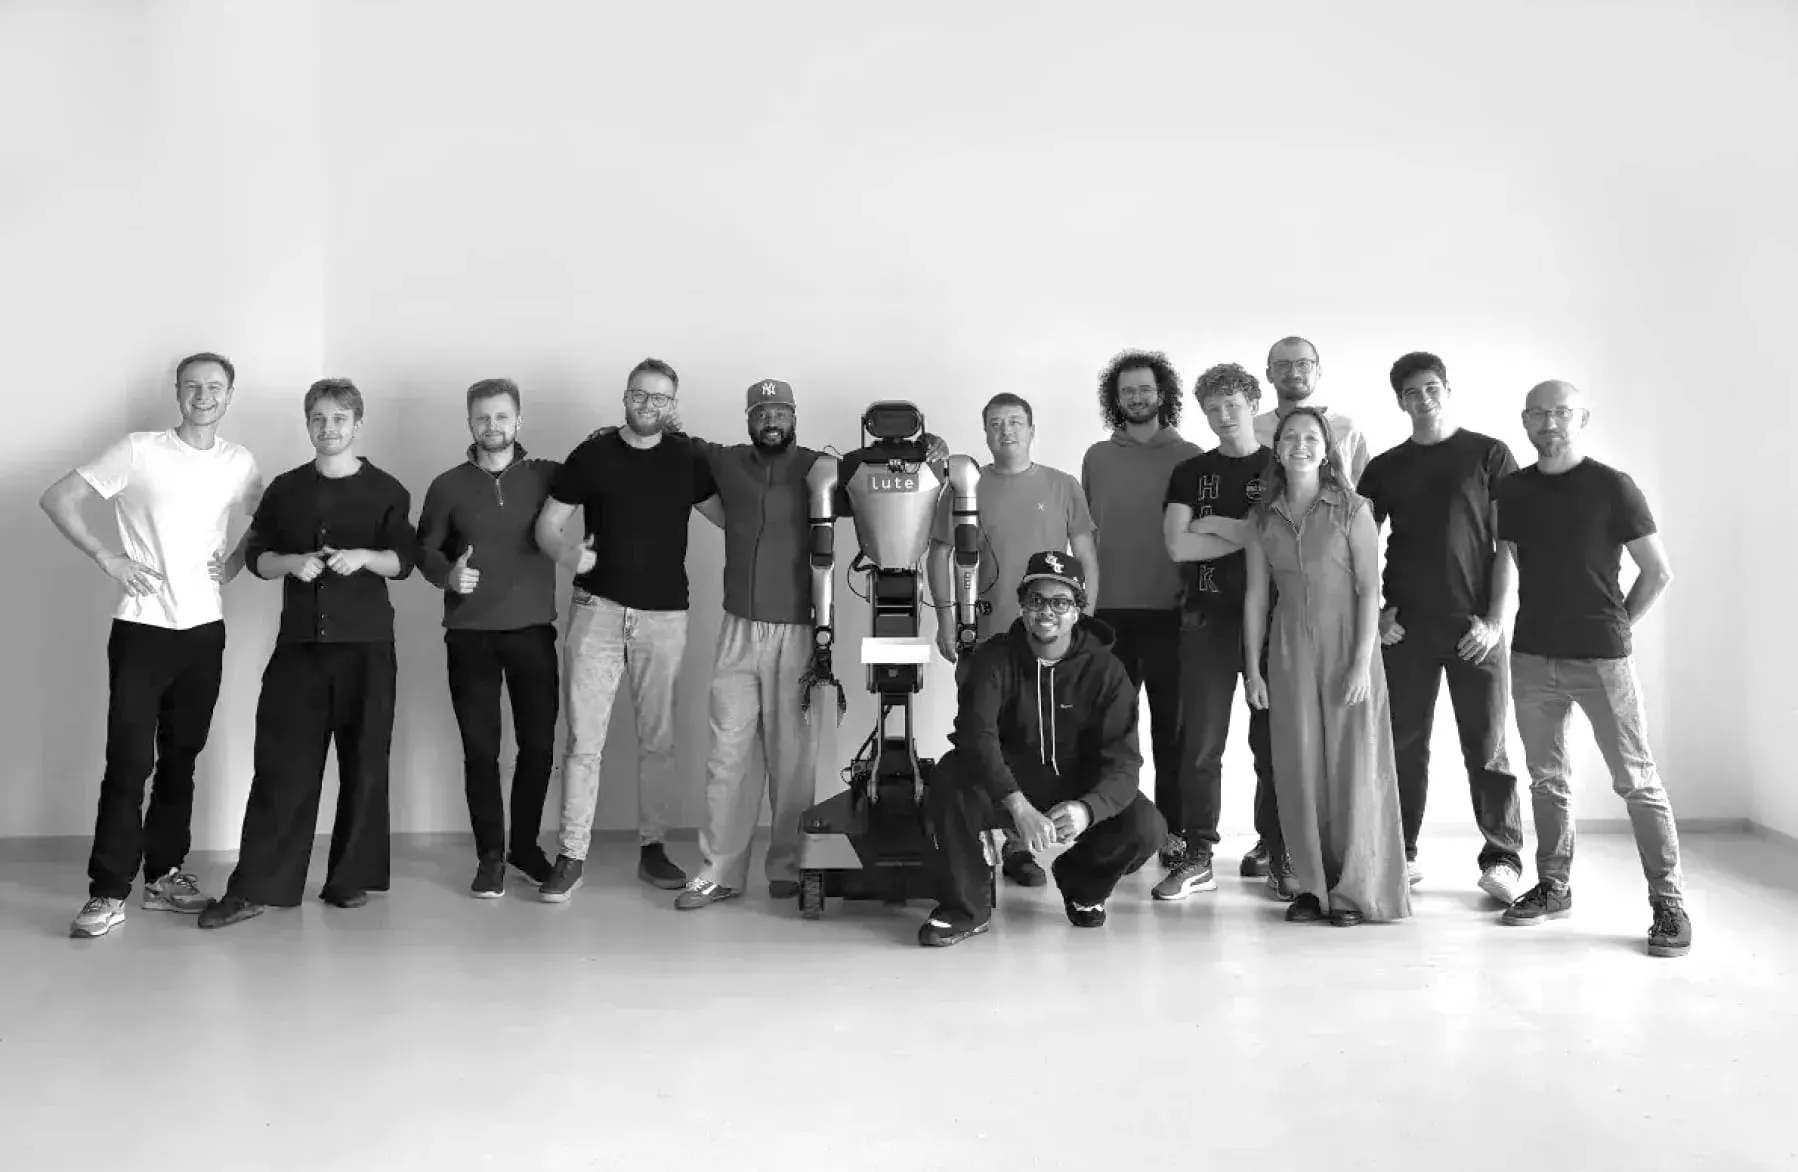
We develop software that enables robotic hardware to perform physical work across real operating environments. Autonomy handles the work whenever possible, while monitoring and remote human support provide a path to completion when intervention is needed.
Our approach starts with the operation, not the robot. We work around customer workflows, constraints, labor availability, and economics, pairing the right hardware with Lute software and support to create a solution that makes sense in practice.
Every deployment also creates data. Edge cases, interventions, and operational feedback feed a continuous learning loop that improves performance, strengthens our models, and expands the range of work physical AI can take on over time.
The potential extends beyond individual automation tasks. As physical AI becomes more capable, it can provide reliable capacity across a growing range of physical work.